superxslam/SuperOdom
Lightweight LiDAR-inertial odometry and mapping on ROS 2

View on index · View in 3D Map
Related repos
- Real-time LiDAR-inertial odometry with compact OctVox mapping
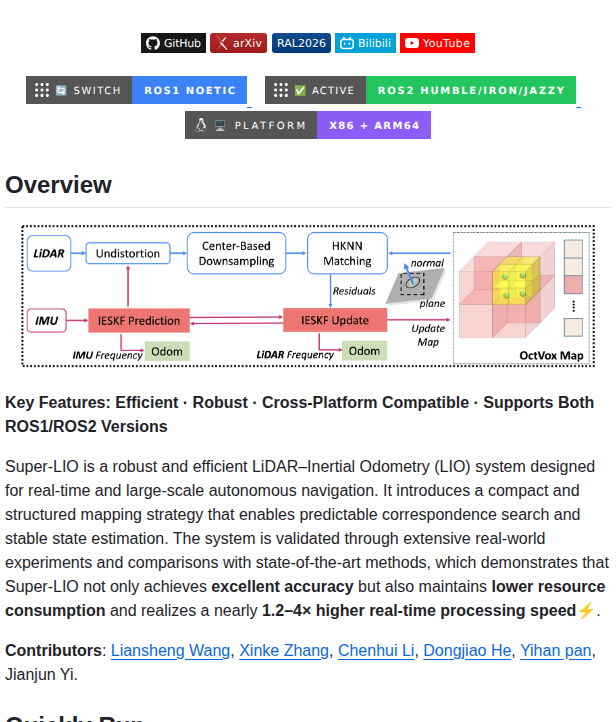
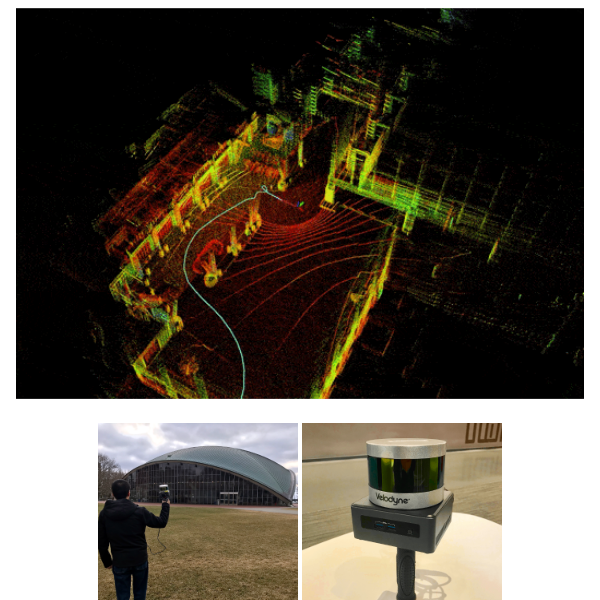
- Real-time lidar-inertial odometry
- LiDAR odometry through data matching
- Fully online visual SLAM for stereo and monocular cameras

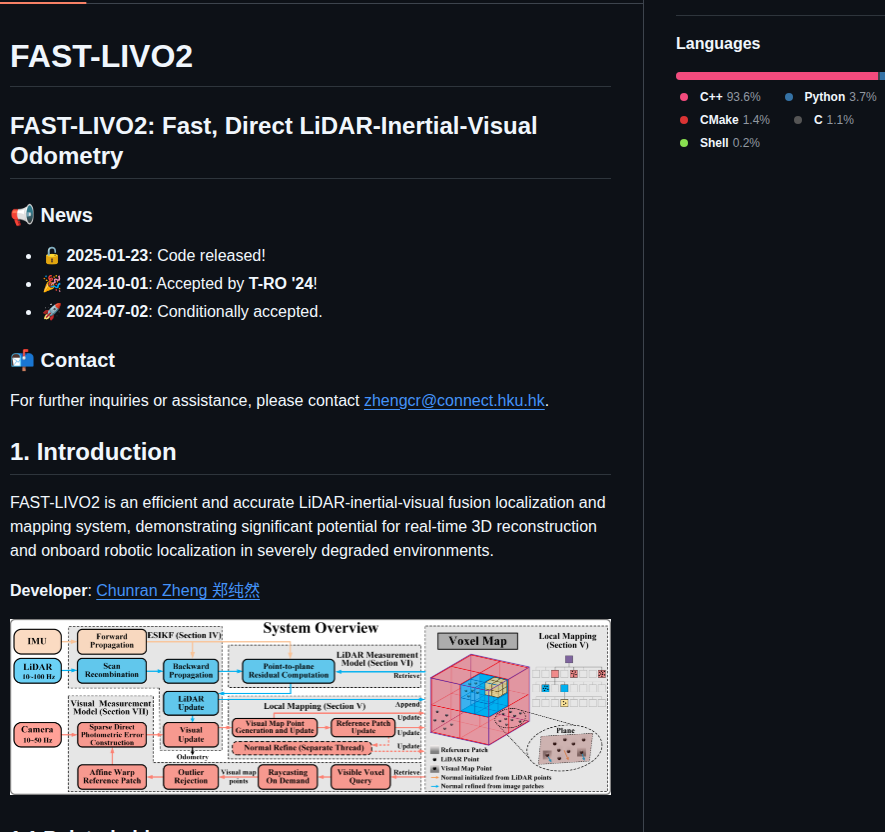
- Direct LiDAR-inertial-visual odometry for real-time 3D reconstruction
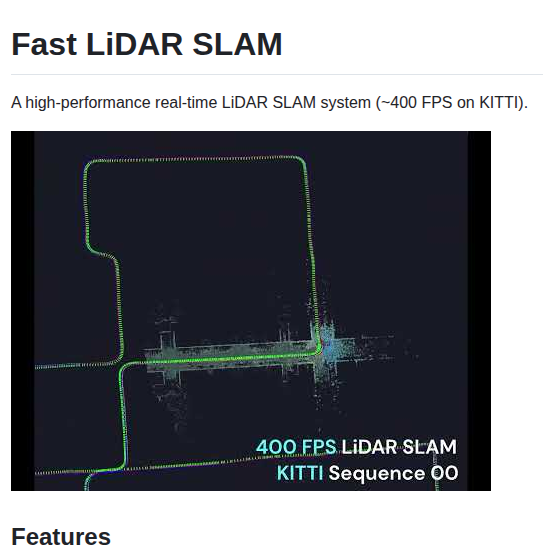
- LiDAR SLAM system with 400 FPS performance
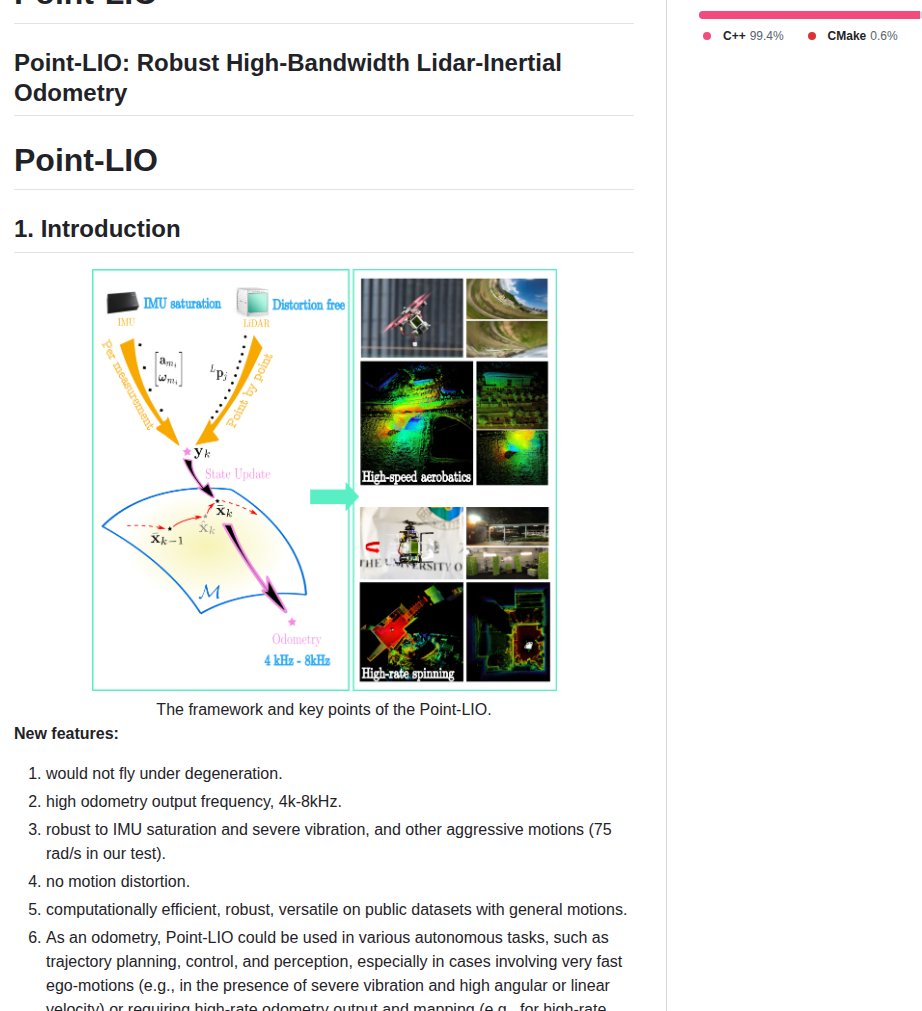
- High-bandwidth LiDAR-inertial odometry at 4-8kHz
- Robust LiDAR odometry using adaptive weighting

- Teaches SLAM mapping and localization with ROS 2 labs

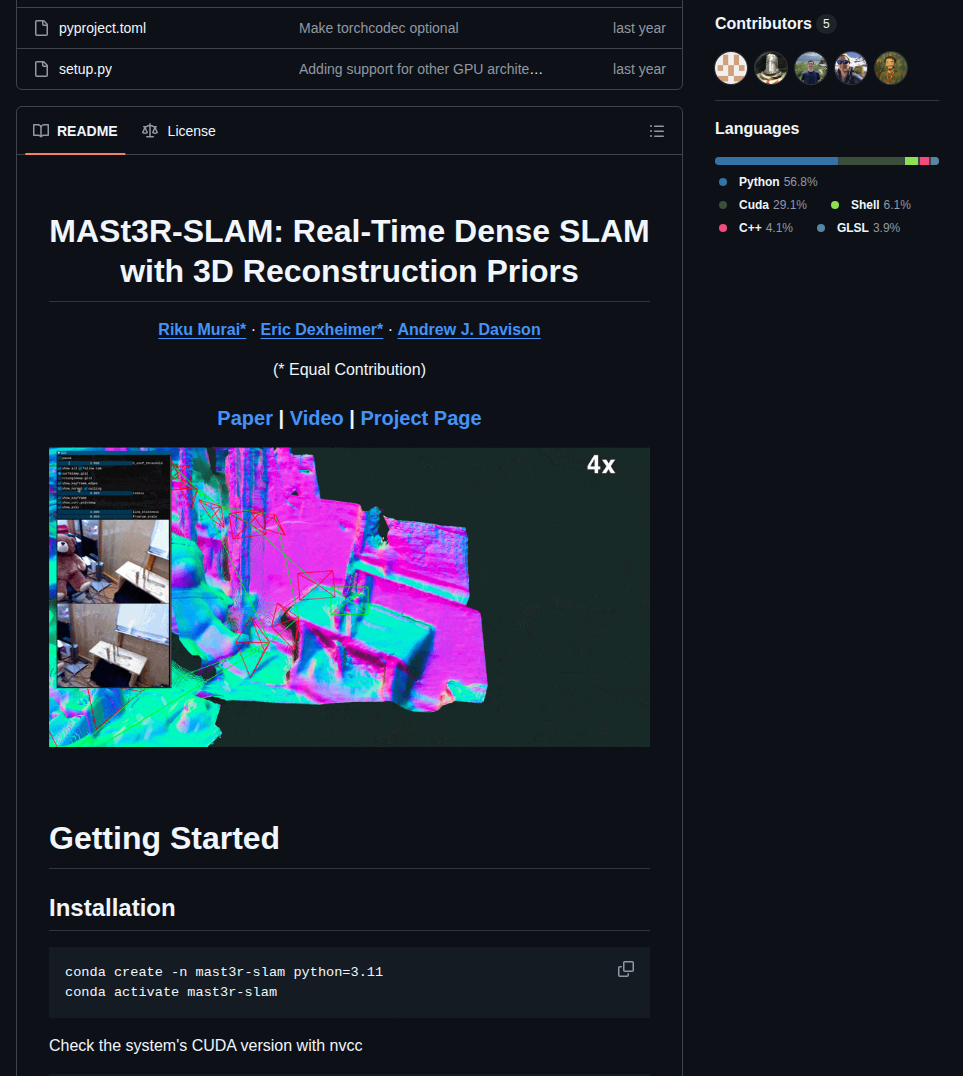
- Generates dense 3D maps in real-time